Upper Limb Rehabilitation Exoskeletons Based On Pneumatic Actuation: A Short Comprehensive Review
DOI:
https://doi.org/10.71229/vman1g95Keywords:
Upper limb exoskeleton,, Pneumatic actuation,, Rehabilitation robots,, Rehabilitation robotics, , Physical rehabilitationAbstract
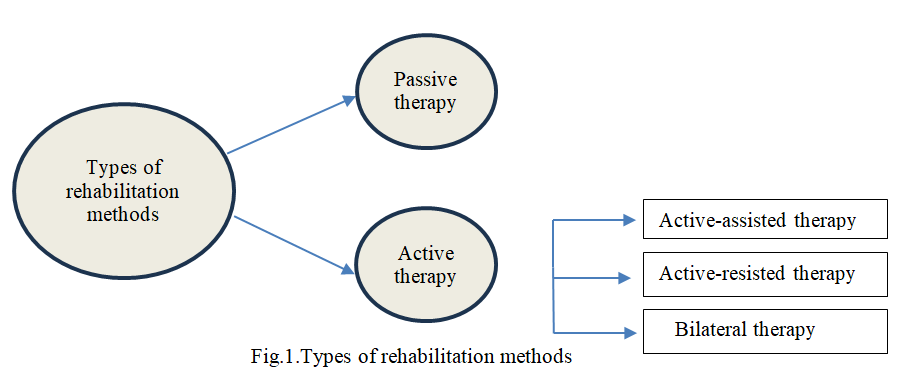
The importance of using robots as an assistant in the physical rehabilitation process, which was physically demanding for therapists, required a lot of time and depended on the health condition of patients, became the main objective of the current paper. In particular, the comparison of different approaches to rehabilitation and actuation strategies and actuation systems used for upper-limb robotic rehabilitation devices with special attention to pneumatic actuation systems became the aim of this research. The comparison was conducted based on the analysis of the characteristics, actuation strategy, advantages, and disadvantages of these systems from 2020 to 2026. As a result, every actuation system and rehabilitation approach had its peculiarities and practical applications. The importance of pneumatic actuation was due to its flexibility, safe human-robot interaction, shock absorption, and lightweight. However, its nonlinearity remained the main disadvantage.
References
[1] C. D. Rocha, I. Carneiro, M. Torres, H. P. Oliveira, E. J. Solteiro Pires, and M. F. Silva, “Post-stroke upper limb rehabilitation: clinical practices, compensatory movements, assessment, and trends,” Prog. Biomed. Eng., vol. 7, no. 4, p. 042001, Oct. 2025, doi: 10.1088/2516-1091/adeb1e.
[2] “EXPERIMENTAL STUDY OF PNEUMATIC DRIVEN EXOSKELETON FOR REHABILITATION AND TRAINING,” J. Theor. Appl. Mech., vol. 55, no. 1, Apr. 2025, doi: 10.55787/jtams.25.55.1.003.
[3] R. Sambhav et al., “An Integrated Dynamic Closed Loop Simulation Platform for Elbow Flexion Augmentation Using an Upper Limb Exosuit Model,” Front. Robot. AI, vol. 9, p. 768841, Mar. 2022, doi: 10.3389/frobt.2022.768841.
[4] F. Missiroli, N. Lotti, M. Xiloyannis, L. H. Sloot, R. Riener, and L. Masia, “Relationship Between Muscular Activity and Assistance Magnitude for a Myoelectric Model Based Controlled Exosuit,” Front. Robot. AI, vol. 7, p. 595844, Dec. 2020, doi: 10.3389/frobt.2020.595844.
[5] C. S. A. Supriyono, M. Dragusanu, and M. Malvezzi, “A Comprehensive Review of Elbow Exoskeletons: Classification by Structure, Actuation, and Sensing Technologies,” Sensors, vol. 25, no. 14, p. 4263, Jul. 2025, doi: 10.3390/s25144263.
[6] T. Butler and J. C. Gillette, “Used as PPE for Injury Prevention,” Prof. Saf. J., Mar. 2019.
[7] T. Butler, “Making Workers Safer and More Productive,” Prof. Saf. J., Sep. 2016.
[8] R. Morales, F. J. Badesa, N. García-Aracil, J. M. Sabater, and C. Pérez-Vidal, “Pneumatic robotic systems for upper limb rehabilitation,” Med. Biol. Eng. Comput., vol. 49, no. 10, pp. 1145–1156, Oct. 2011, doi: 10.1007/s11517-011-0814-3.
[9] H. M. Qassim and W. Z. Wan Hasan, “A Review on Upper Limb Rehabilitation Robots,” Appl. Sci., vol. 10, no. 19, p. 6976, Oct. 2020, doi: 10.3390/app10196976.
[10] S. Dalla Gasperina, L. Roveda, A. Pedrocchi, F. Braghin, and M. Gandolla, “Review on Patient-Cooperative Control Strategies for Upper-Limb Rehabilitation Exoskeletons,” Front. Robot. AI, vol. 8, p. 745018, Dec. 2021, doi: 10.3389/frobt.2021.745018.
[11] M. A. Gull, S. Bai, and T. Bak, “A Review on Design of Upper Limb Exoskeletons,” Robotics, vol. 9, no. 1, p. 16, Mar. 2020, doi: 10.3390/robotics9010016.
[12] E. Hays et al., “A Review of Rehabilitative and Assistive Technologies for Upper-Body Exoskeletal Devices,” Actuators, vol. 12, no. 4, p. 178, Apr. 2023, doi: 10.3390/act12040178.
[13] D. Chiaradia, G. Rinaldi, M. Solazzi, R. Vertechy, and A. Frisoli, “Design and Control of the Rehab-Exos, a Joint Torque-Controlled Upper Limb Exoskeleton,” Robotics, vol. 13, no. 2, p. 32, Feb. 2024, doi: 10.3390/robotics13020032.
[14] G. Ma, H. Jia, J. Xiao, and L. Hao, “A Method for Precise Tracking Control of Pneumatic Artificial-Muscle-Driven Exoskeletal Robot,” Appl. Sci., vol. 13, no. 21, p. 12038, Nov. 2023, doi: 10.3390/app132112038.
[15] M. Tiboni, A. Borboni, F. Vérité, C. Bregoli, and C. Amici, “Sensors and Actuation Technologies in Exoskeletons: A Review,” Sensors, vol. 22, no. 3, p. 884, Jan. 2022, doi: 10.3390/s22030884.
[16] T. Kosaki, S. Li, and Department of Systems Engineering, Graduate School of Information Sciences, Hiroshima City University 3-4-1 Ozuka-higashi, Asaminami-ku, Hiroshima 731-3194, Japan, “A Water-Hydraulic Upper-Limb Assistive Exoskeleton System with Displacement Estimation,” J. Robot. Mechatron., vol. 32, no. 1, pp. 149–156, Feb. 2020, doi: 10.20965/jrm.2020.p0149.
[17] Q. Y. Hamid, W. Z. Wan Hasan, M. A. Azmah Hanim, A. A. Nuraini, M. N. Hamidon, and H. R. Ramli, “Shape memory alloys actuated upper limb devices: A review,” Sens. Actuators Rep., vol. 5, p. 100160, Jun. 2023, doi: 10.1016/j.snr.2023.100160.
[18] H.-B. Park, D.-R. Kim, H.-J. Kim, W. Wang, M.-W. Han, and S.-H. Ahn, “Design and Analysis of Artificial Muscle Robotic Elbow Joint Using Shape Memory Alloy Actuator,” Int. J. Precis. Eng. Manuf., vol. 21, no. 2, pp. 249–256, Feb. 2020, doi: 10.1007/s12541-019-00240-8.
[19] D. M. G. Preethichandra et al., “Passive and Active Exoskeleton Solutions: Sensors, Actuators, Applications, and Recent Trends,” Sensors, vol. 24, no. 21, p. 7095, Nov. 2024, doi: 10.3390/s24217095.
[20] J. Chen and P. S. Lum, “Pilot testing of the spring operated wearable enhancer for arm rehabilitation (SpringWear),” J. NeuroEngineering Rehabil., vol. 15, no. 1, p. 13, Dec. 2018, doi: 10.1186/s12984-018-0352-4.
[21] L. Song, C. Ju, H. Cui, Y. Qu, X. Xu, and C. Chen, “Research on Control Strategy Technology of Upper Limb Exoskeleton Robots: Review,” Machines, vol. 13, no. 3, p. 207, Mar. 2025, doi: 10.3390/machines13030207.
[22] Q. Liu et al., “Path Planning and Impedance Control of a Soft Modular Exoskeleton for Coordinated Upper Limb Rehabilitation,” Front. Neurorobotics, vol. 15, p. 745531, Nov. 2021, doi: 10.3389/fnbot.2021.745531.
[23] G. Mashud, S. Hasan, and N. Alam, “Advances in Control Techniques for Rehabilitation Exoskeleton Robots: A Systematic Review,” Actuators, vol. 14, no. 3, p. 108, Feb. 2025, doi: 10.3390/act14030108.
[24] L. D. L. Da Silva, T. F. Pereira, V. R. Q. Leithardt, L. O. Seman, and C. A. Zeferino, “Hybrid Impedance-Admittance Control for Upper Limb Exoskeleton Using Electromyography,” Appl. Sci., vol. 10, no. 20, p. 7146, Oct. 2020, doi: 10.3390/app10207146.
[25] B. Kalita, A. Leonessa, and S. K. Dwivedy, “A Review on the Development of Pneumatic Artificial Muscle Actuators: Force Model and Application,” Actuators, vol. 11, no. 10, p. 288, Oct. 2022, doi: 10.3390/act11100288.
[26] A. Zhagiparova, V. Golubev, and D. Kim, “Recent Developments in Pneumatic Artificial Muscle Actuators,” Actuators, vol. 14, no. 12, p. 582, Dec. 2025, doi: 10.3390/act14120582.
[27] É. Bowness and M. Doumit, “Soft pneumatic actuators for wearable systems: a structural classification and integration-oriented evaluation,” Prog. Biomed. Eng., vol. 8, no. 2, p. 022017, Jun. 2026, doi: 10.1088/2516-1091/ae6d5e.
[28] C.-T. Chen, W.-Y. Lien, C.-T. Chen, and Y.-C. Wu, “Implementation of an Upper-Limb Exoskeleton Robot Driven by Pneumatic Muscle Actuators for Rehabilitation,” Actuators, vol. 9, no. 4, p. 106, Oct. 2020, doi: 10.3390/act9040106.
[29] C.-T. Chen, W.-Y. Lien, C.-T. Chen, M.-J. Twu, and Y.-C. Wu, “Dynamic Modeling and Motion Control of a Cable-Driven Robotic Exoskeleton With Pneumatic Artificial Muscle Actuators,” IEEE Access, vol. 8, pp. 149796–149807, 2020, doi: 10.1109/ACCESS.2020.3016726.
[30] S. Syafeeq Lone, N. Zainul Azlan, and N. Kamarudzaman, “Soft Pneumatic Exoskeleton for Wrist and Thumb Rehabilitation,” Int. J. Robot. Control Syst., vol. 1, no. 4, pp. 440–452, Oct. 2021, doi: 10.31763/ijrcs.v1i4.447.
[31] Q. Liu et al., “Design and Control of a Reconfigurable Upper Limb Rehabilitation Exoskeleton With Soft Modular Joints,” IEEE Access, vol. 9, pp. 166815–166824, 2021, doi: 10.1109/ACCESS.2021.3136242.
[32] H.-R. Chu, S.-J. Chiou, I.-H. Li, and L.-W. Lee, “Design, Development, and Control of a Novel Upper-Limb Power-Assist Exoskeleton System Driven by Pneumatic Muscle Actuators,” Actuators, vol. 11, no. 8, p. 231, Aug. 2022, doi: 10.3390/act11080231.
[33] X. Chen, S. Zhang, K. Cao, C. Wei, W. Zhao, and J. Yao, “Development of a Wearable Upper Limb Rehabilitation Robot Based on Reinforced Soft Pneumatic Actuators,” Chin. J. Mech. Eng., vol. 35, no. 1, p. 83, Dec. 2022, doi: 10.1186/s10033-022-00749-6.
[34] F. Durante, T. Raparelli, and P. Beomonte Zobel, “Two-Dof Upper Limb Rehabilitation Robot Driven by Straight Fibers Pneumatic Muscles,” Bioengineering, vol. 9, no. 8, p. 377, Aug. 2022, doi: 10.3390/bioengineering9080377.
[35] C.-M. Biriș, S.-G. Racz, C.-E. Gîrjob, R.-D. Grovu, and D.-M. Rusu, “A Wearable Device for Upper Limb Rehabilitation and Assistance Based on Fluid Actuators and Myoelectric Control,” Appl. Sci., vol. 13, no. 18, p. 10181, Sep. 2023, doi: 10.3390/app131810181.
[36] T. Ridremont et al., “Pneumatically Actuated Soft Robotic Hand and Wrist Exoskeleton for Motion Assistance in Rehabilitation,” Actuators, vol. 13, no. 5, p. 180, May 2024, doi: 10.3390/act13050180.
[37] C. Yao, J. Ma, M. Wang, Y. Yang, S. Yin, and D. Chen, “Design, Fabrication, and Evaluation of Rigid-Soft Coupled Pneumatic Actuators for Upper Limb Rehabilitation,” in 2025 IEEE International Conference on Real-time Computing and Robotics (RCAR), Toyama, Japan: IEEE, Jun. 2025, pp. 462–466. doi: 10.1109/RCAR65431.2025.11139759.
[38] H. Zhang, N. Yu, J. Han, and Y. Qin, “Adaptive Fault-Tolerant Control With Prescribed Performance for an Upper Limb Rehabilitation Exoskeleton Driven by Pneumatic Artificial Muscles,” IEEE Trans. Syst. Man Cybern. Syst., vol. 55, no. 12, pp. 9580–9590, Dec. 2025, doi: 10.1109/TSMC.2025.3619079.
[39] D.-M. Rusu, S.-D. Mândru, S.-G. Racz, C.-E. Gîrjob, C.-M. Biriș, and M. Crenganiș, “Wearable exoskeleton upper limb device based on soft actuators: design, characterization, and preliminary testing,” Bioinspir. Biomim., vol. 21, no. 4, p. 046028, Aug. 2026, doi: 10.1088/1748-3190/ae8fc2.
[40] V. Potnik, G. Frediani, M. Dimitri, and F. Carpi, “Hand Rehabilitation Dynamic Splint with Variable Force via Pneumatic Artificial Muscle Actuators,” Ann. Biomed. Eng., Jun. 2026, doi: 10.1007/s10439-026-04233-3.
Downloads
Published
Issue
Section
License
Copyright (c) 2026 Al-Noor Journal of Engineering Management and Computer Science

This work is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.
How to Cite